Curriculum
AP Physics C: Mechanics
1. Kinematics
0/11
2. Force and Translational Dynamics
0/21
3. Work, Energy, and Power
0/11
4. Linear Momentum
0/9
5. Torque and Rotational Dynamics
0/13
-
5. Torque and Rotational Dynamics
 Preview
-
5.1 Rotational Kinematics
Preview
-
5.1 Rotational Kinematics - Check yourself
 Preview
-
5.2 Connecting Linear and Rotational Motion
Preview
-
5.2 Connecting Linear and Rotational Motion - Check yourself
Preview
-
5.3 Torque
Preview
-
5.3 Torque - Check yourself
Preview
-
5.4 Rotational Inertia
Preview
-
5.4 Rotational Inertia - Check yourself
Preview
-
5.5 Rotational Equilibrium and Newton’s First Law in Rotational Form
Preview
-
5.5 Rotational Equilibrium and Newton’s First Law in Rotational Form - Check yourself
Preview
-
5.6 Newton’s Second Law in Rotational Form
Preview
-
5.6 Newton’s Second Law in Rotational Form - Check yourself
Preview
6. Energy and Momentum of Rotating Systems
0/13
7. Oscillations
0/11
Text lesson
5. Torque and Rotational Dynamics
Unit 5 Torque and Rotational Dynamics — AP PHYSICS C: MECHANICS notes: You will be able to connect the six topics of Unit 5 by describing rotation with angular kinematics, relating angular and linear quantities, calculating torque and rotational inertia, and applying the rotational forms of Newton’s first and second laws.
1Unit 5 at a glance2Unit 5 at a glance
1Rotational kinematics and its link to linear motion2Rotational kinematics and its link to linear motion3Rotational kinematics and its link to linear motion4Rotational kinematics and its link to linear motion5Rotational kinematics and its link to linear motion
1Torque and the causes of rotational change2Torque and the causes of rotational change3Torque and the causes of rotational change4Torque and the causes of rotational change
Torque and the causes of rotational change
Torque and the causes of rotational change
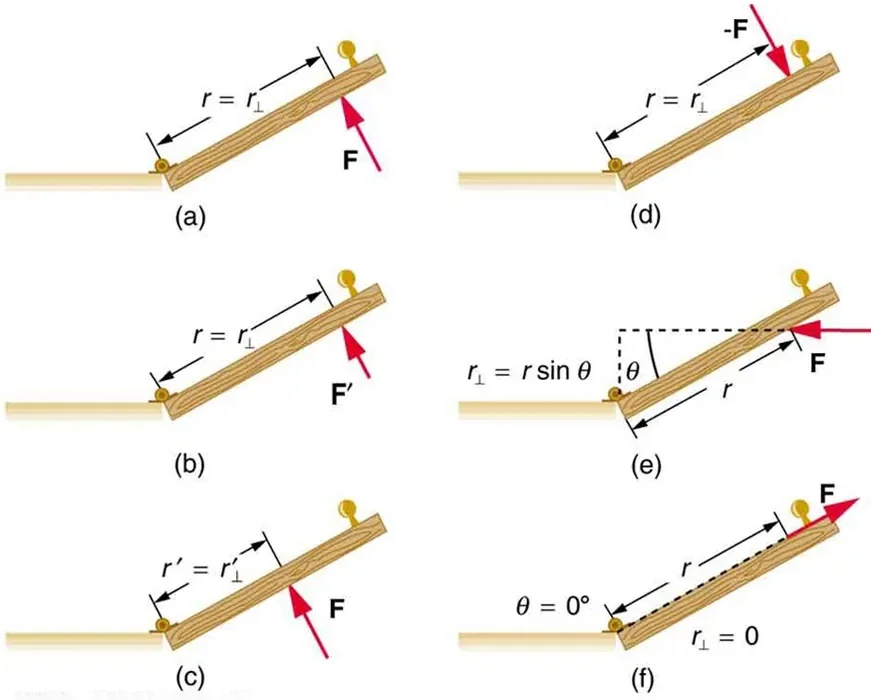
A force causes rotation only through its perpendicular component, measured by its lever arm.
1 / 4Next ▶
Torque and the causes of rotational change
Torque and the causes of rotational change
The torque about a pivot is
τ
=
rF
sin
θ
◀ Previous2 / 4Next ▶
Torque and the causes of rotational change
Torque and the causes of rotational change
, or equivalently
r
⊥
F
, and the cross product
×
◀ Previous3 / 4Next ▶
Torque and the lever arm: A force on a rod at different angles and positions, showing how the lever arm sets the torque.
Torque and the causes of rotational change
 ⤢ Enlarge
1
gives its magnitude and direction (topic 5.3).
2
Net torque is the sum of the torques of all forces about a common pivot.
3
Its sign depends on the convention chosen, and this unit takes counterclockwise as positive throughout.
◀ Previous4 / 4
1Rotational inertia2Rotational inertia3Rotational inertia4Rotational inertia
1Rotational equilibrium and the rotational laws of motion2Rotational equilibrium and the rotational laws of motion3Rotational equilibrium and the rotational laws of motion
1How the topics connect2How the topics connect
Key equations of Unit 5
Key equations of Unit 5
Values used in Unit 5 examples: g = 10 m/s2, the value used in the AP Physics C: Mechanics course framework.
| Equation | Symbols and SI units | Topic |
|---|---|---|
| ω = dθ/dt; α = dω/dt | θ angular position (rad); ω angular velocity (rad/s); α angular acceleration (rad/s2); t time (s) | 5.1 |
| ω = ω0 + αt; θ − θ0 = ω0t + ½αt2; ω2 = ω02 + 2α(θ − θ0); θ − θ0 = ½(ω0 + ω)t | Angular position and velocity (rad, rad/s) with constant α (rad/s2) | 5.1 |
| s = rθ; vt = rω; at = rα | s arc length (m); r radius (m); vt tangential speed (m/s); at tangential acceleration (m/s2) | 5.2 |
| ac = v2/r = rω2 | ac radial acceleration (m/s2), directed towards the axis | 5.2 |
| τ = rF sin θ = r⊥F; τ = r × F | τ torque (N·m); r distance from pivot (m); F force (N); θ angle between r and F; r⊥ lever arm (m) | 5.3 |
| I = Σmr2; I = ∫r2 dm | I rotational inertia (kg·m2); m mass (kg); r perpendicular distance from axis (m) | 5.4 |
| I = MR2 (hoop); ½MR2 (solid disk); ML2/12 and ML2/3 (rod about centre and end) | M mass (kg); R radius (m); L length (m) | 5.4 |
| I = Icm + Md2 | Icm rotational inertia about the centre of mass (kg·m2); d distance between parallel axes (m) | 5.4 |
| Στ = 0 | Rotational equilibrium: constant angular velocity; net torque in N·m | 5.5 |
| Στ = Iα | Στ net torque (N·m); I rotational inertia (kg·m2); α angular acceleration (rad/s2) | 5.6 |
Key terms
| Term | Meaning |
|---|---|
| Rigid system | A system whose points keep fixed distances from one another, so that all its points rotate together. |
| Torque | The turning effect of a force about a pivot, equal to rF sin θ and measured in newton metres. |
| Lever arm | The perpendicular distance from the axis of rotation to the line of action of a force. |
| Rotational inertia | The resistance of a rigid system to changes in its rotation, which depends on its mass and how that mass is distributed. |
| Rotational equilibrium | The condition in which the net torque on a rigid system is zero, so its angular velocity is constant. |
| Angular acceleration | The rate at which angular velocity changes, measured in radians per second squared. |
| Non-slip condition | The relation a = Rα between the linear acceleration of a rope and the angular acceleration of the wheel over which it runs without slipping. |
| Parallel axis theorem | The relation I = Icm + Md2 between rotational inertias about parallel axes. |
1Avoid these mistakes2Avoid these mistakes3Avoid these mistakes4Avoid these mistakes